NVIDIA Uses AI Agents to Teach Tiny Walking Robot to Navigate Obstacles
By automating obstacle-course training in simulation, NVIDIA aims to reduce development work, though real-world performance remains unproven.
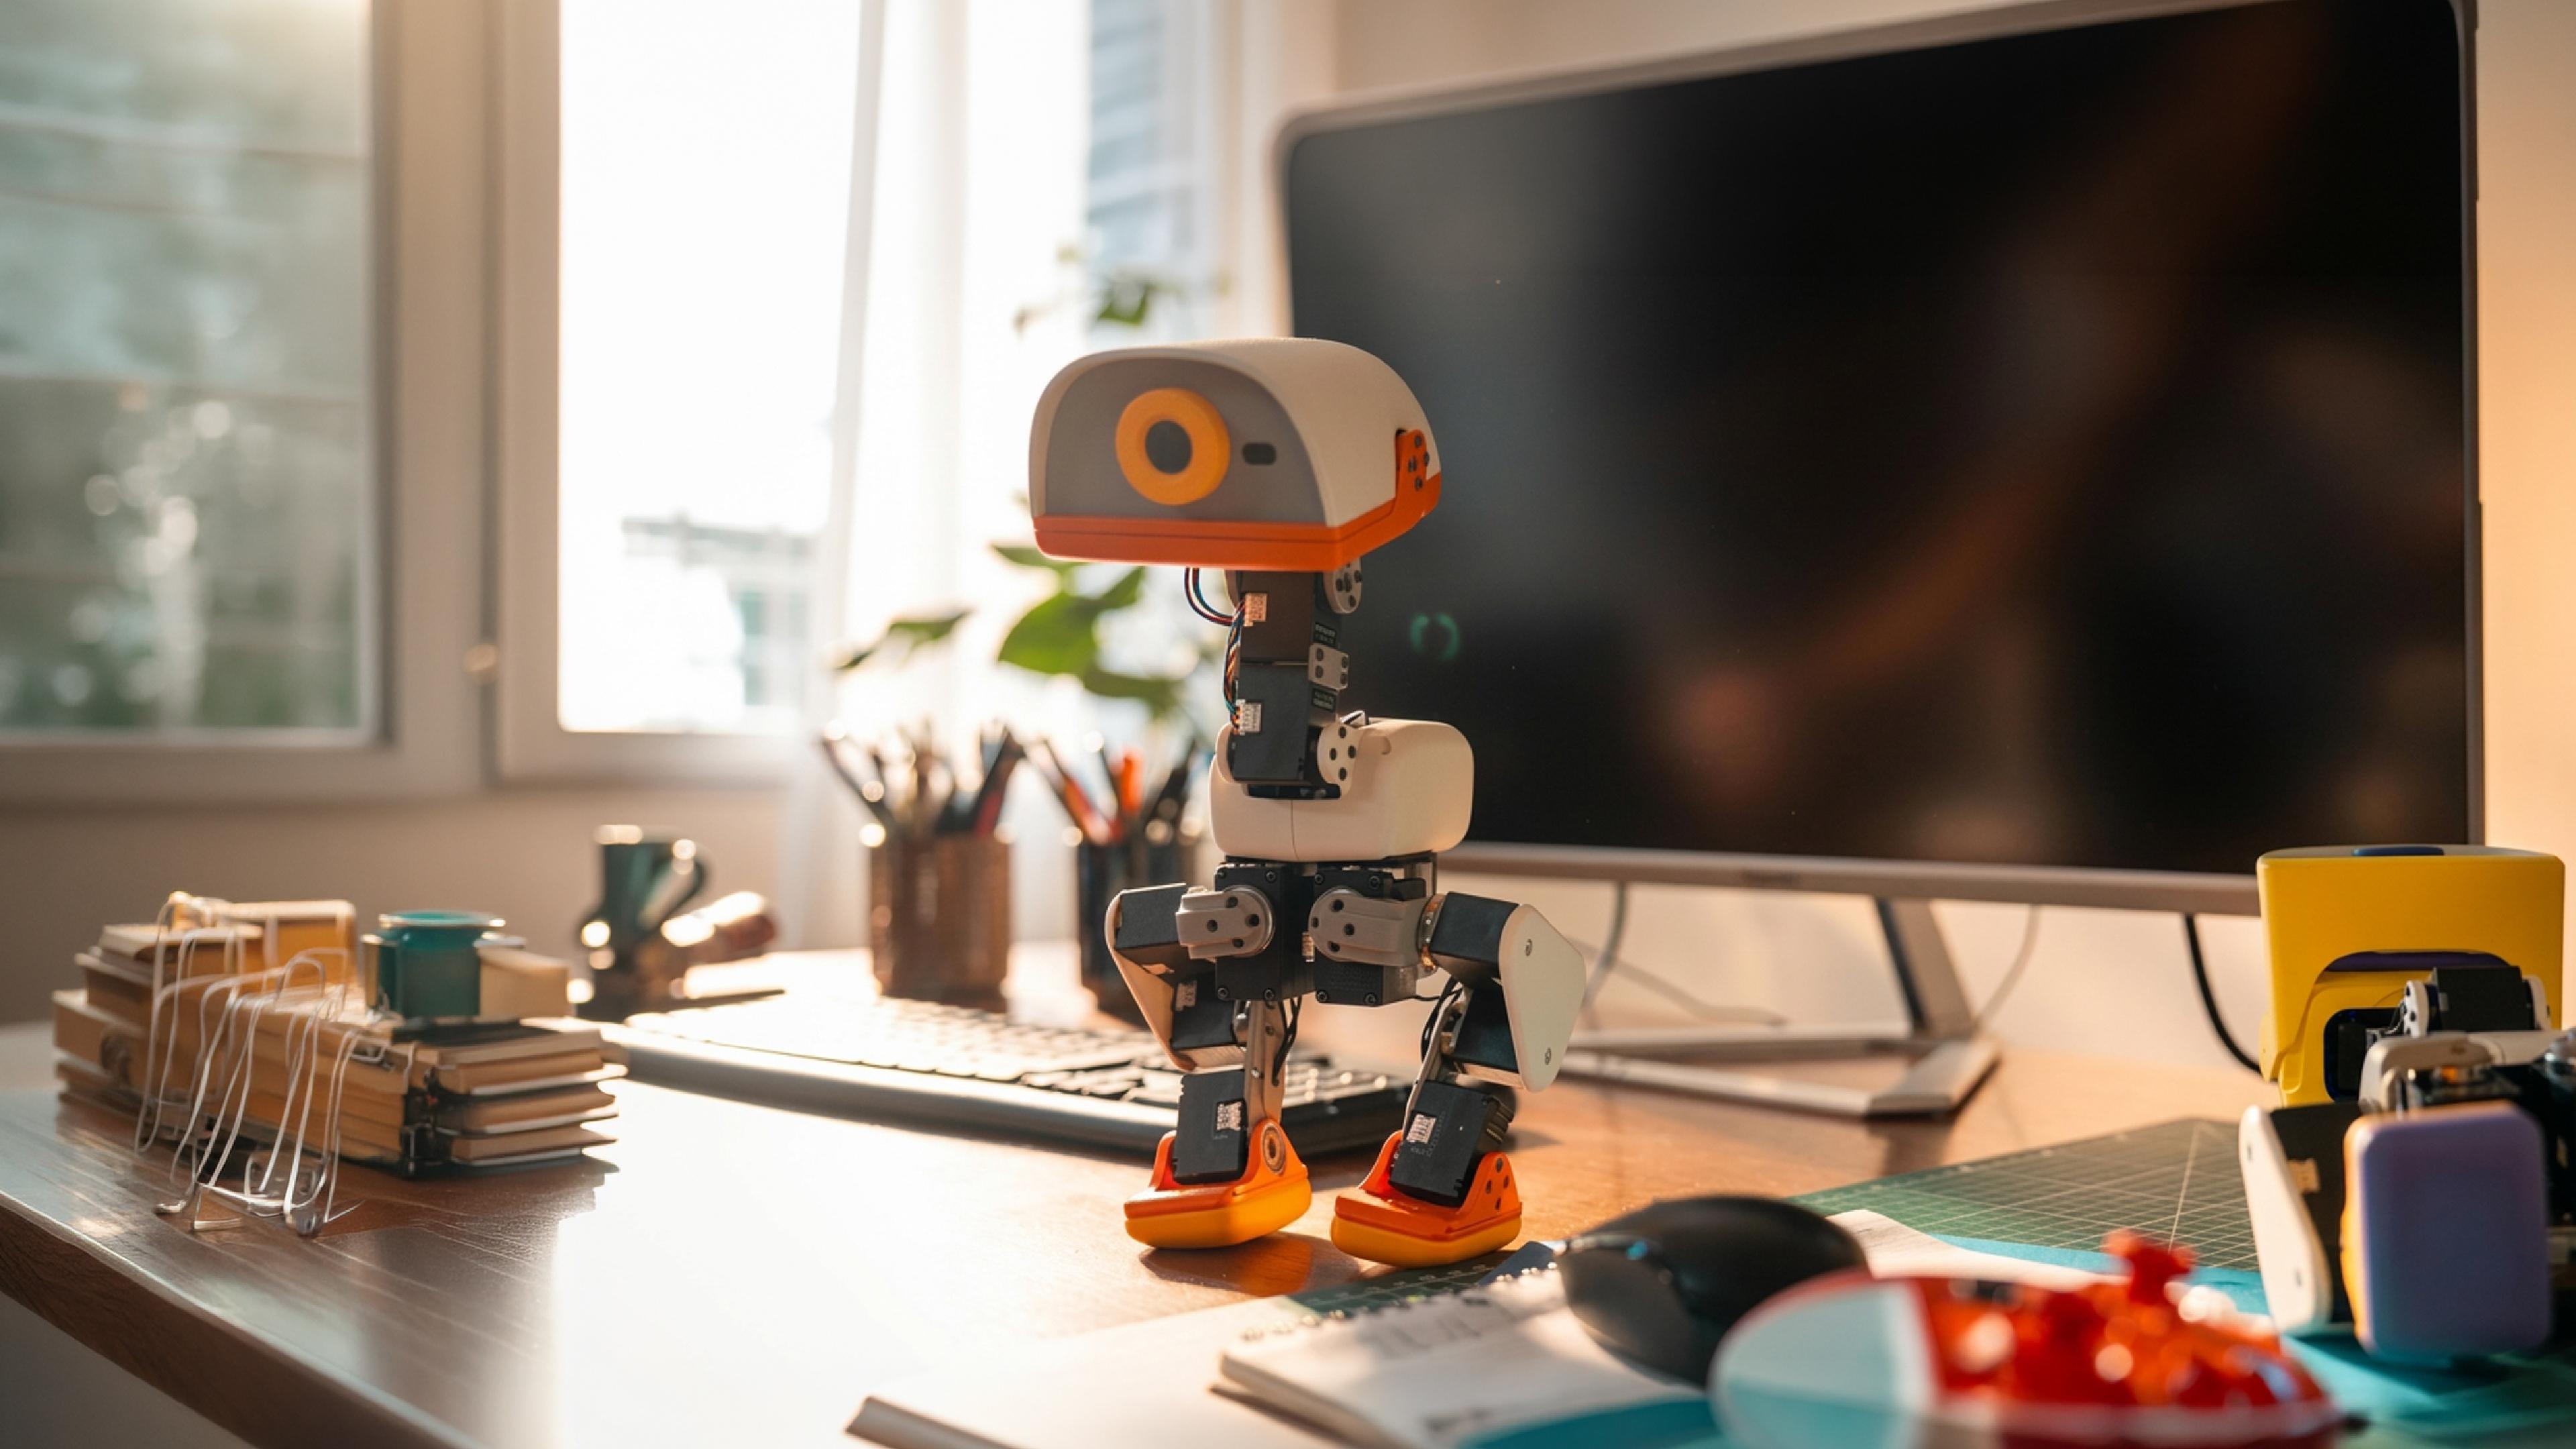
In a demonstration of an AI-assisted training process, NVIDIA has demonstrated how a little two-legged robot can be taught to make its way around obstacles in simulation, all within one workflow that covers several stages of robot development.
The Microduck Demonstration
The company made the demonstration public on October 23 with Microduck, the compact bipedal robot from Pollen Robotics of France, as its subject. It is an illustration of how AI agents can help build training environments and get robots ready to move in different ways.
Less Manual Setup for Developers
Developers don’t have to build the training process by hand; they are able to set out what they want a robot to learn and use AI agents to organize the steps needed to create and test it. For their part, NVIDIA had Microduck put through an obstacle course of ramps, uneven ground and platforms, all while maintaining its balance.
How the Workflow Starts
Hermes and NVIDIA’s Nemotron 3.5 Bolt come in first, turning a written request into a development plan. Then an AI agent called Astra will take that plan and aid in making the three-dimensional objects required for the environment. All of this comes together in NVIDIA Isaac Sim where the robot is free to engage with a virtual obstacle course and its simulated physics.
Learning by Trial and Error
Reinforcement learning is applied by NVIDIA Isaac Lab to the robot’s movement controller when the environment has been set up. The virtual robot is not told what to do at each step but learns by trying the obstacles again and again; it is rewarded for successful movements and given feedback in the event of a fall or collision to improve its behavior.
Training at Scale, Then Testing
NVIDIA ran 4,096 parallel simulations on an RTX PRO 6000 Blackwell Workstation Edition GPU for the experiment. In this way, the controller was exposed to different conditions as thousands of simulated versions of Microduck were at practice simultaneously. Information on body position and movement were taken in along with what the robot’s head-mounted depth camera could observe.
An evaluation in Isaac Sim followed to see if the controller would have the robot recognize an obstacle and alter its course to finish it.
Simulation vs. the Real World
A physical Microduck was also shown walking under the direction of a locomotion controller from Isaac Lab. But NVIDIA did not establish that the newly trained obstacle-navigation controller had completed the same course on a physical robot.
There is reason for that distinction since what a machine does in the real world is not always a straight copy of its simulation, motor response and sensor data being among the variables.
Techniques to narrow such differences have been outlined by NVIDIA, like variations in the physical parameters of the simulation and actuator models of greater precision.
What the Demonstration Shows
What the demonstration makes clear is how much manual work AI agents can take off the setup of a robot’s training environment, freeing developers to attend to the physical side of things.
What Still Needs Testing
As it stands, the results from the obstacle navigation remain simulation-based and will require more testing in the physical realm to determine the system’s reliability.
More articles on this topic
223 articles ReportWhat it Really Costs to Own a Personal Assistant Robot at Home
 ReportHumanoids Struggle With Unfamiliar Chores, New Research Finds
 ReportQuadruped Solves Giant Rubik’s Cube Using Only Its Feet
 ReportScientists Develop System to Help Robots Gesture Without Losing Balance
 ReportRobotic Fish Offer New Way to Track River Pollution
 ReportHigh Torque Robotics Partners With Sharebot to Expand Humanoid Access Across China
 ReportAudi Tests Agile Robots' Mobile Humanoids for Factory Logistics
 ReportFrom Flips to Dance Moves: New AI Trains Humanoid Robots in Record Time
 ReportHow a Tiny Robot Searches for Hidden Damage Inside the Wind Turbine Blades
 ReportRadioactive Mess? Better Call Spot
 ReportJapan's LOVOT Companion Robot Makes Abu Dhabi Healthcare Debut
 ReportTesla Starts Optimus Production, Targets First Commercial Deliveries in 2027
BUSINESS NEWS WEEKLY LETTER
The Weekly Letter for Robotics Professionals, Summarizing the Most Important Industry Moves, Launches, Deals and Signals.