Quadruped Solves Giant Rubik’s Cube Using Only Its Feet
By combining vision, AI and precise movements, the robot completed a complex puzzle without hands, opening new possibilities for quadrupeds.
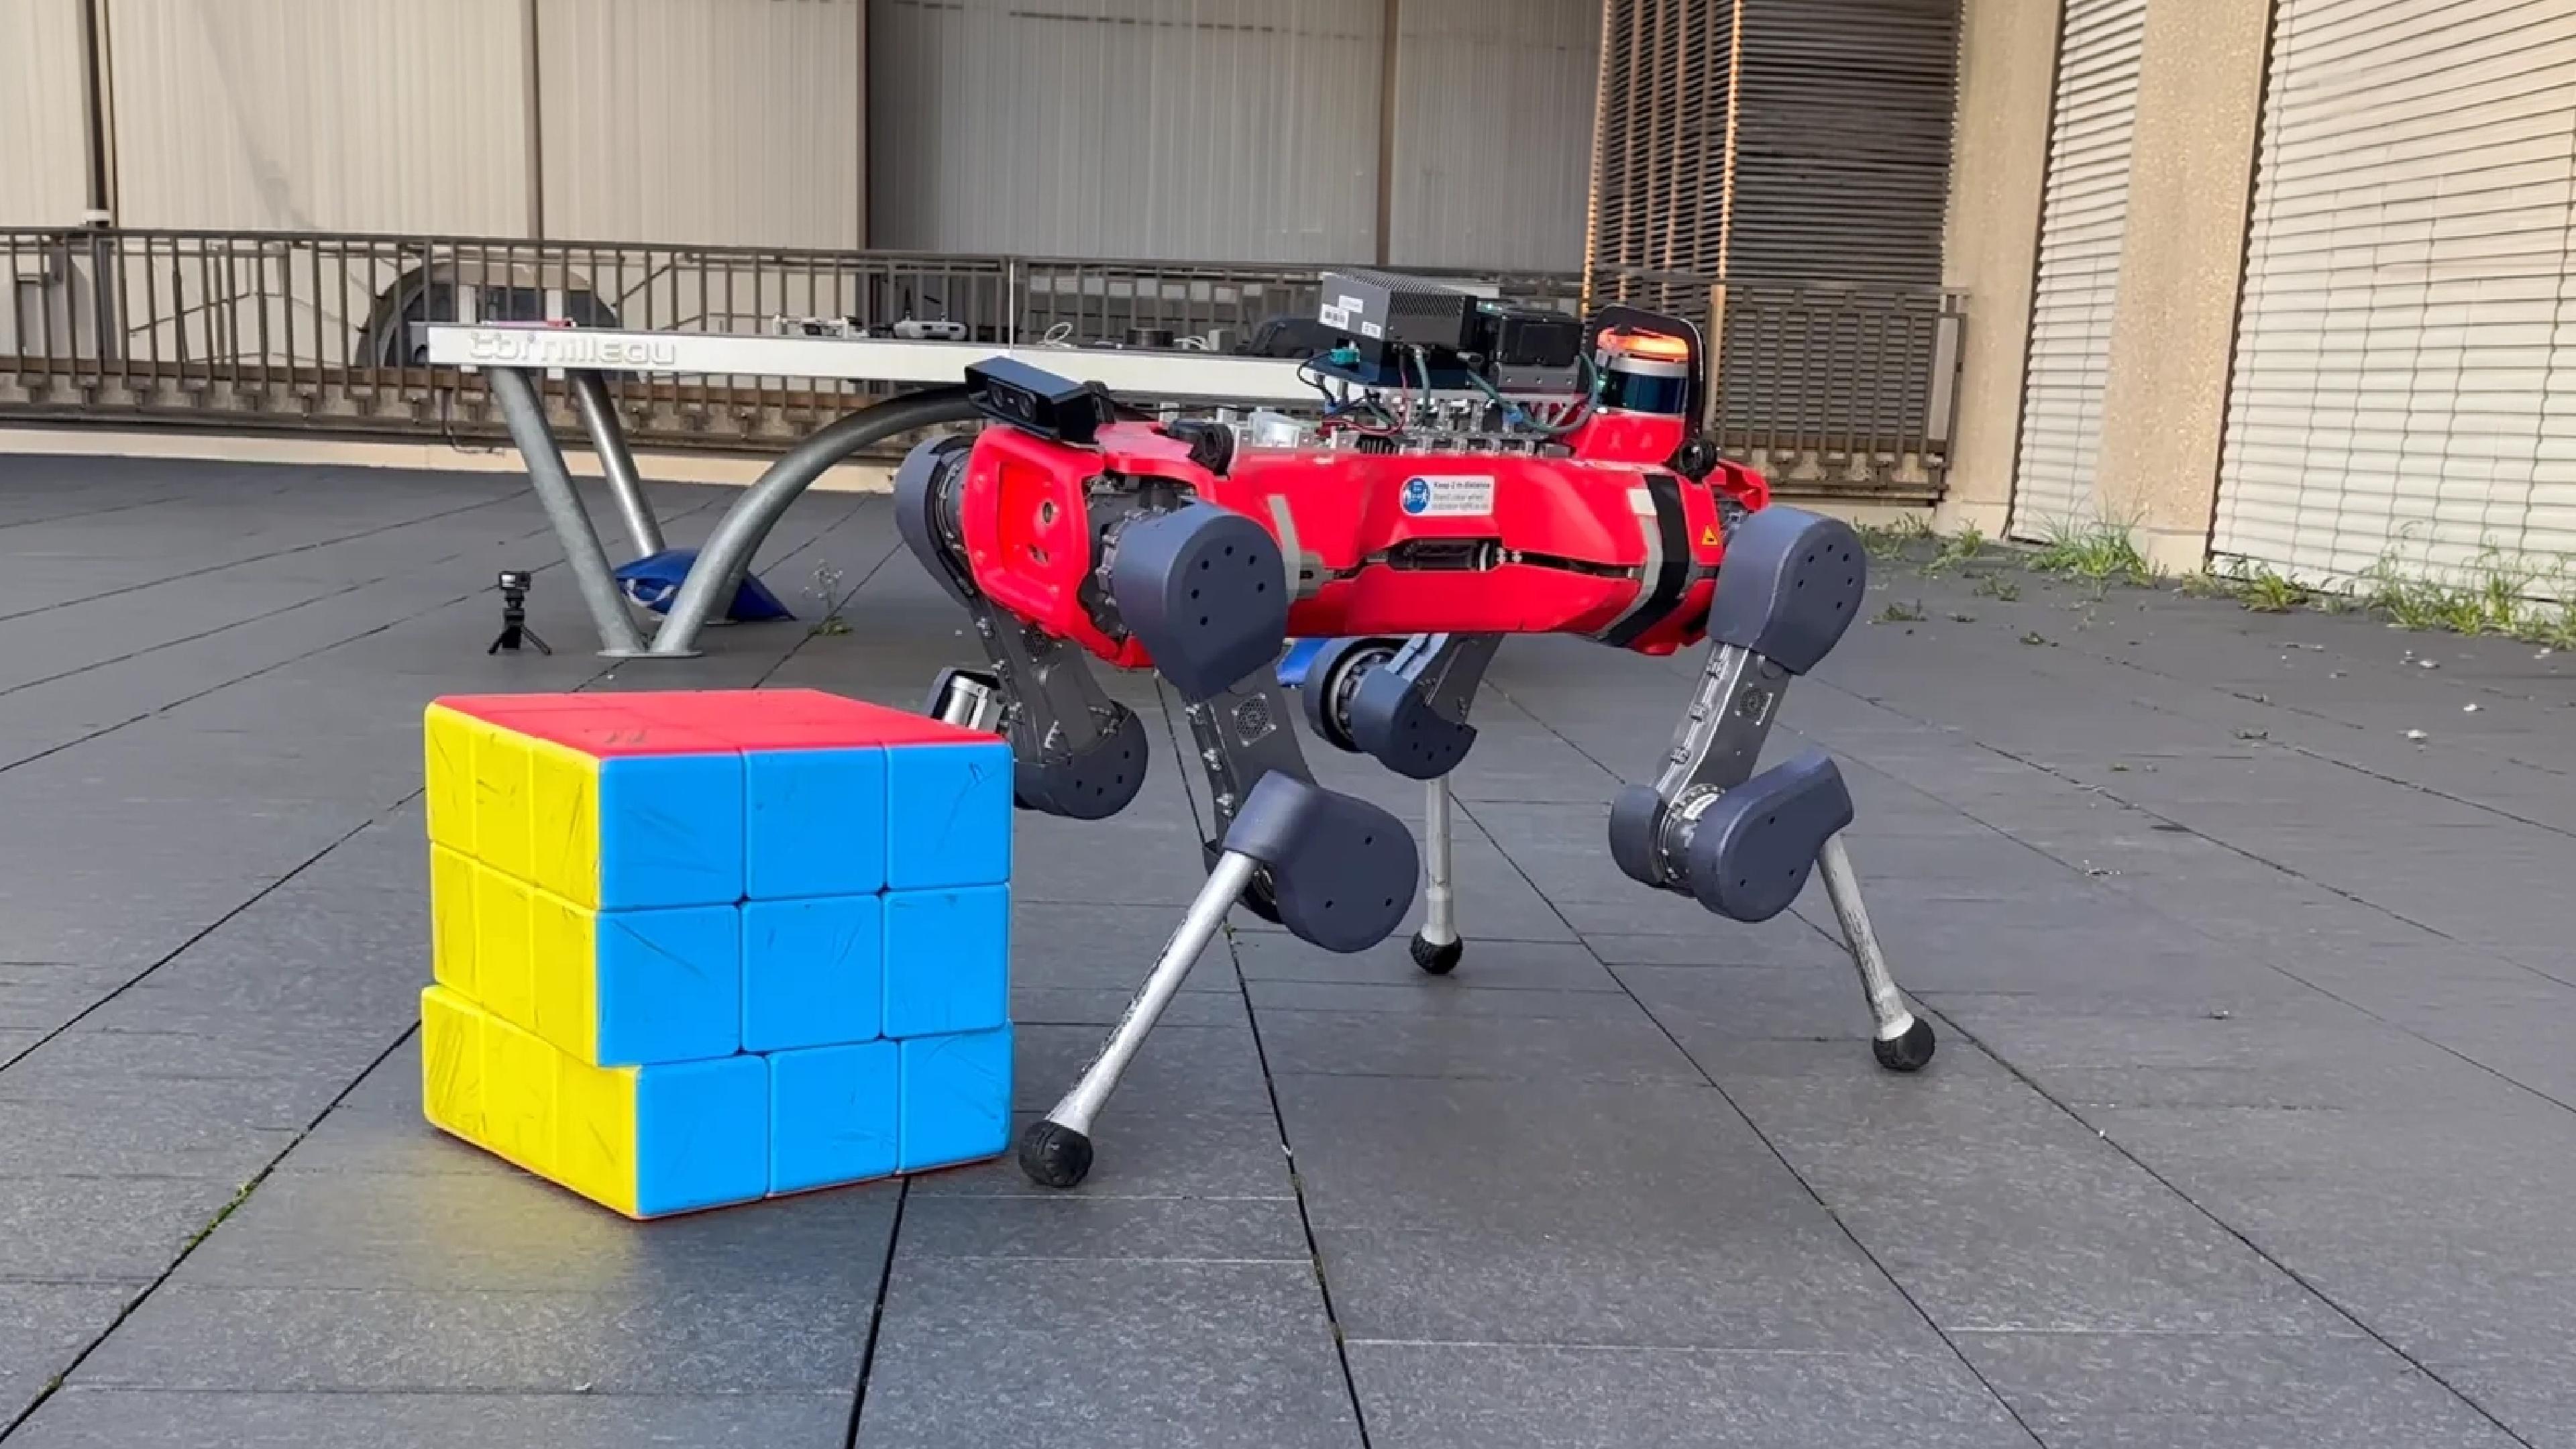
A team of researchers from ETH Zurich has developed a four-legged robot that can solve a giant Rubik’s Cube all on its own, using its feet to rotate and reposition the puzzle.
It is an example of how quadruped robots can perform precise manipulation tasks when they do not have robotic hands or other additional attachments. The approach was laid out in a research paper published on October 17; it is a system of computer vision, motion planning and reinforcement learning that enables the robot to make sense of the cube, work out a solution and execute the necessary movements.
For their part, the researchers had an ANYmal-D quadruped complete three autonomous solves of the physical cube. Around 30 steps were required for each, and the process took between eight and nine minutes. A conventional cube-solving machine would not have to worry about its balance while tending to the puzzle, but this robot must.
The procedure starts with the robot putting its depth sensors and cameras to work to get a good look at the cube from every side. In this manner, it can pick out the colours, piece together the configuration and determine the moves to be made. What follows is the execution of those moves through the skills it has been taught. The robot might tip the cube to show another face or, to turn a layer, brace the cube with one foot while using another to push the required section into position. Such coordination is no easy matter since an unintended rotation would spoil the puzzle and any further progress.
Before being transferred to the physical robot, its controllers were put through their paces in a simulation via reinforcement learning. Visual feedback is employed to keep the robot in the right position from one movement to the next.
The research team says the robot has shown itself resilient to some external disturbances and variations in its position relative to the cube. They have also put the learned movements to the test on different surfaces and with a misaligned cube.
One might see the solving of a Rubik’s Cube as something of an entertainment-focused achievement, but the experiment is really about a more fundamental problem in robotics, namely, getting a machine to manipulate things with its whole body.
Quadrupeds are made for mobility in terrain that would confound wheels. If they can be taught to employ their legs for manipulation, there is scope for more than just walking and inspection down the line.
That said, the robot was working with a set of trained skills and a specially designed puzzle; it does not establish that the robot can independently manipulate unfamiliar objects in everyday environments.
The results bear witness to a four-legged robot using perception and coordinated movement to see a complicated task through without the need for special hardware.
More articles on this topic
223 articles ReportWhat it Really Costs to Own a Personal Assistant Robot at Home
 ReportHumanoids Struggle With Unfamiliar Chores, New Research Finds
 ReportNVIDIA Uses AI Agents to Teach Tiny Walking Robot to Navigate Obstacles
 ReportScientists Develop System to Help Robots Gesture Without Losing Balance
 ReportRobotic Fish Offer New Way to Track River Pollution
 ReportHigh Torque Robotics Partners With Sharebot to Expand Humanoid Access Across China
 ReportAudi Tests Agile Robots' Mobile Humanoids for Factory Logistics
 ReportFrom Flips to Dance Moves: New AI Trains Humanoid Robots in Record Time
 ReportHow a Tiny Robot Searches for Hidden Damage Inside the Wind Turbine Blades
 ReportRadioactive Mess? Better Call Spot
 ReportJapan's LOVOT Companion Robot Makes Abu Dhabi Healthcare Debut
 ReportTesla Starts Optimus Production, Targets First Commercial Deliveries in 2027
BUSINESS NEWS WEEKLY LETTER
The Weekly Letter for Robotics Professionals, Summarizing the Most Important Industry Moves, Launches, Deals and Signals.