How Do Robots See the World?
A robot has to work all of this out from sensor data. First, it identifies the object and understands where it is. Then, it decides what to do with the object; for example, whether to move towards it, avoid it, or pick it up. That's the problem machine vision helps robots solve. Let's break it down.

September 23, 2026 by Anju
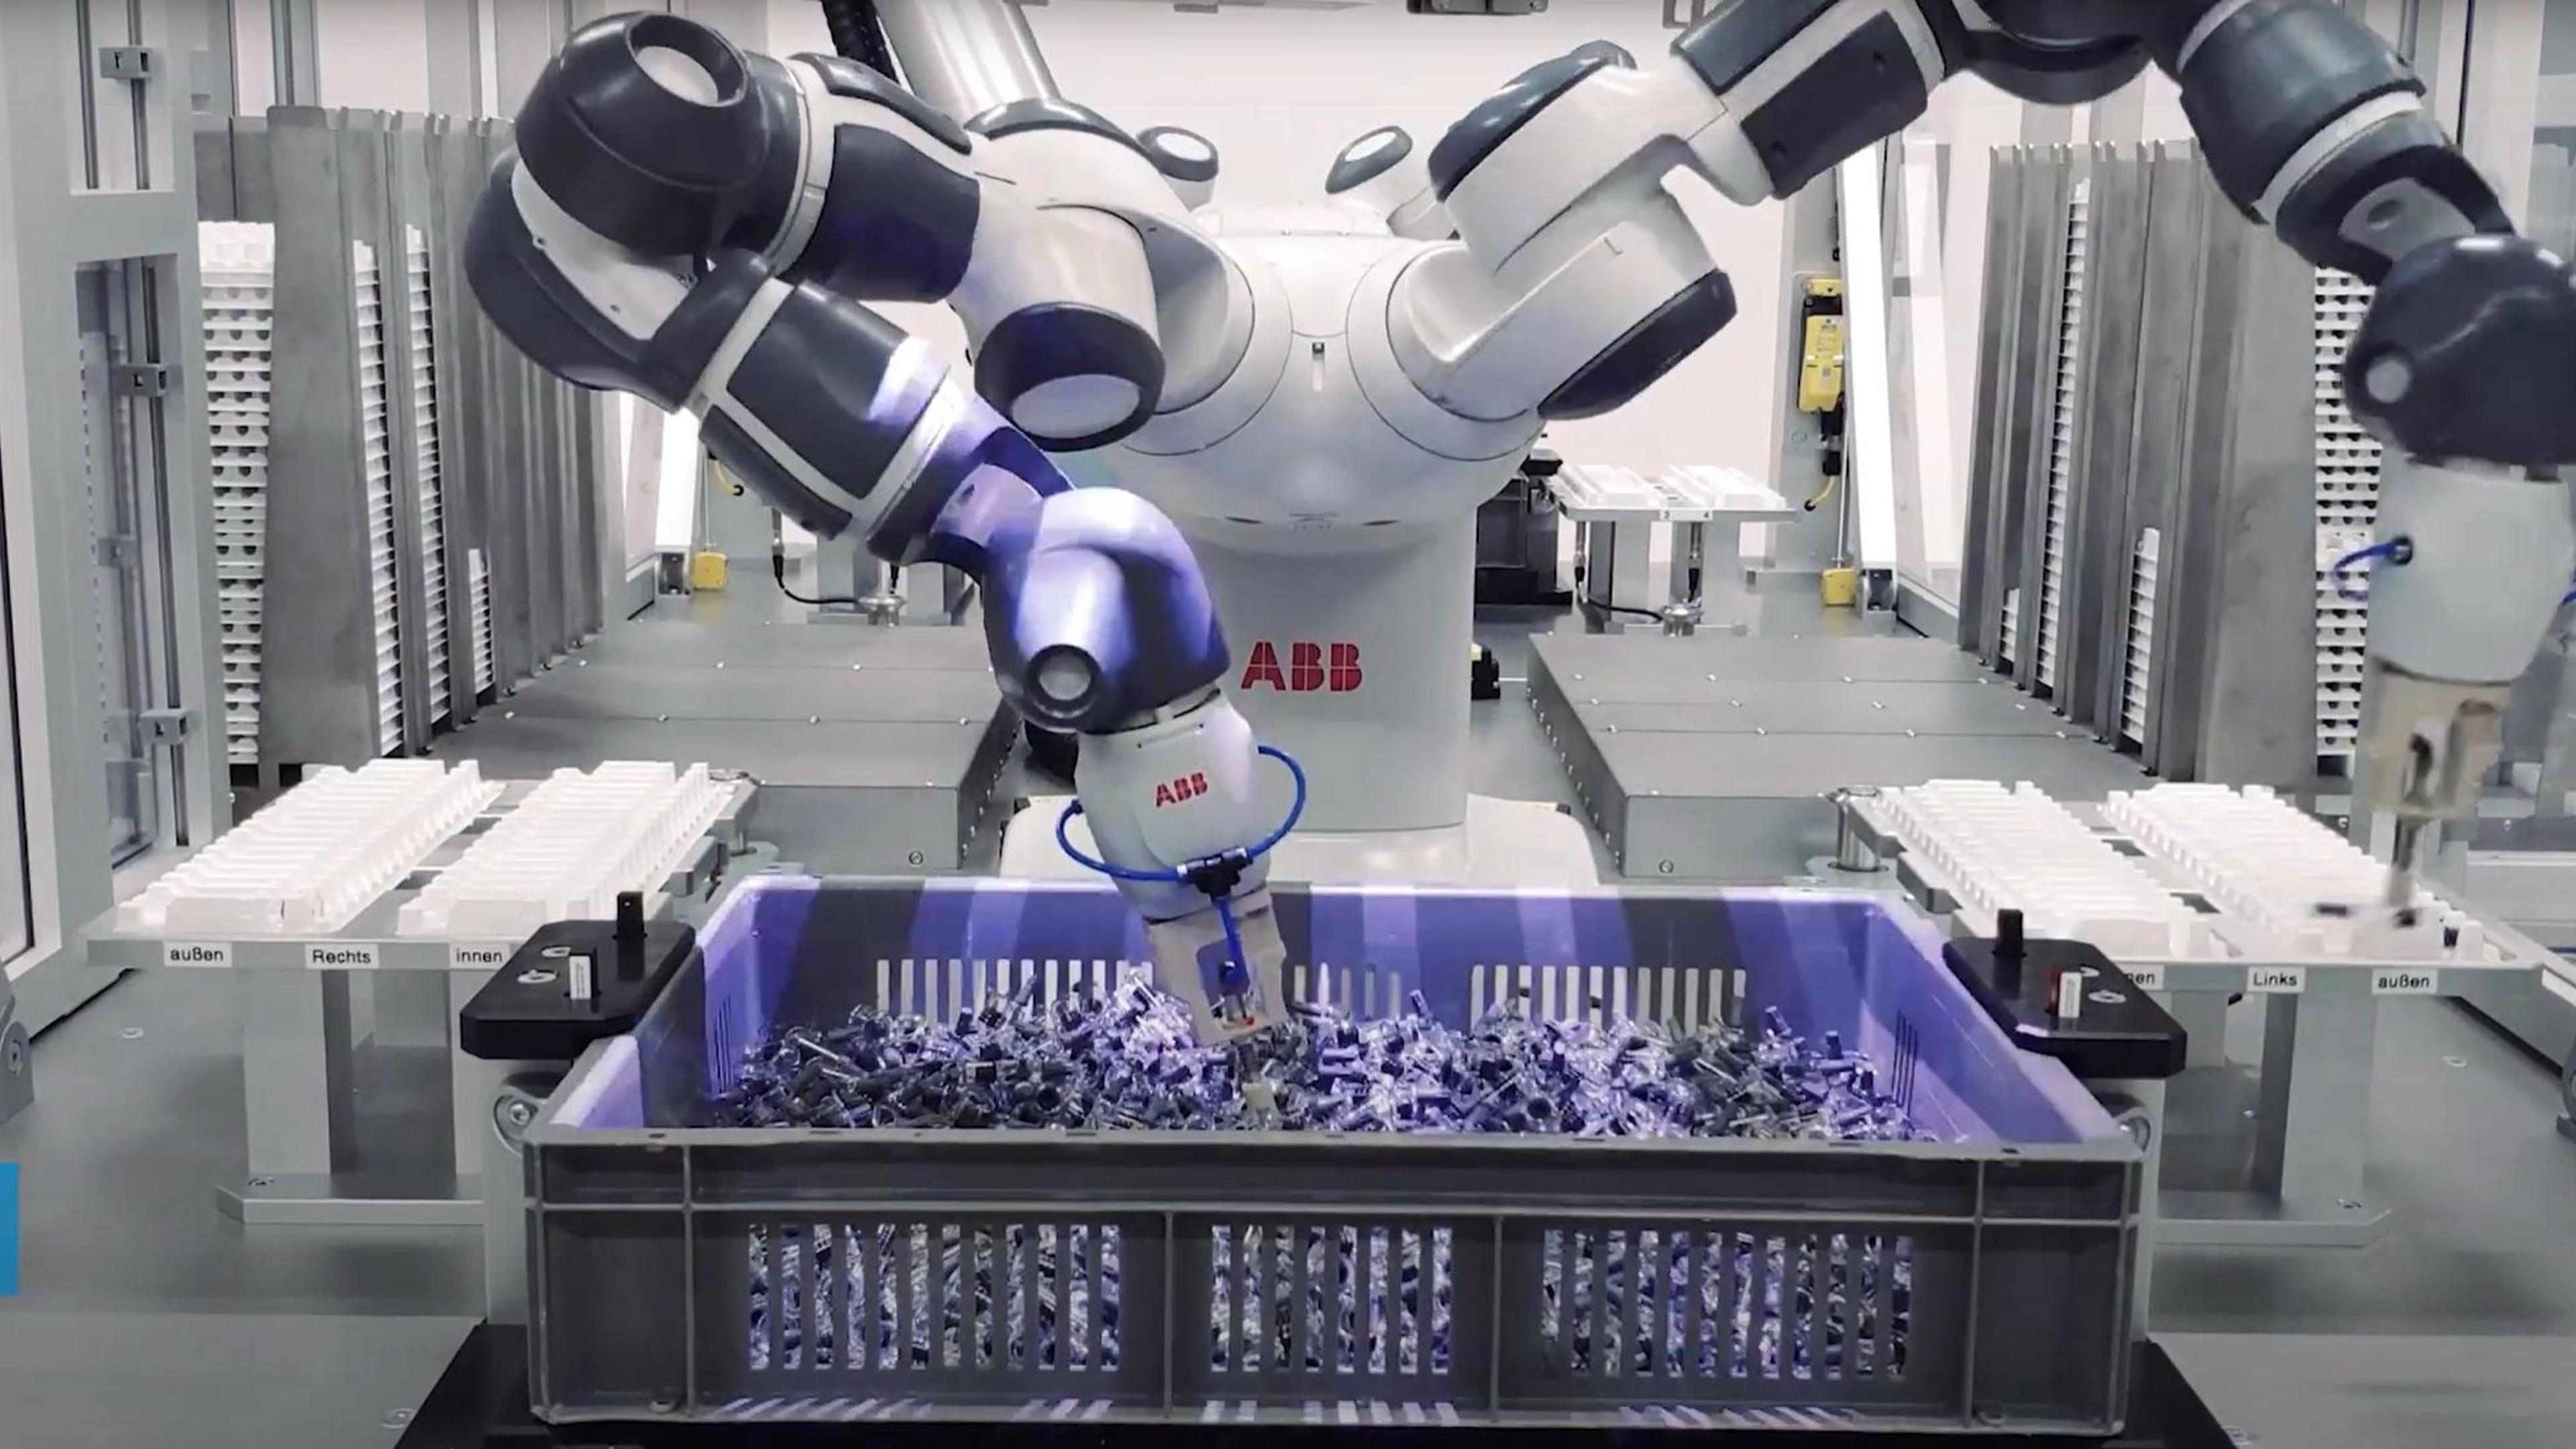
The Robot Captures An Image
First, the robot captures an image of its surroundings. A robot may use an RGB camera, depth camera, stereo cameras, LiDAR, or a combination of sensors.
Take a warehouse robot. A normal camera can show that there is a box in front of it, but the robot also needs to know how far away the box is. A depth camera provides that extra information.
A self-driving vehicle has a much harder job. Waymo's autonomous driving system uses cameras, LiDAR, and radar together. Cameras show what is around the vehicle. LiDAR maps the surroundings in 3D, while radar detects nearby objects and tracks their movement.
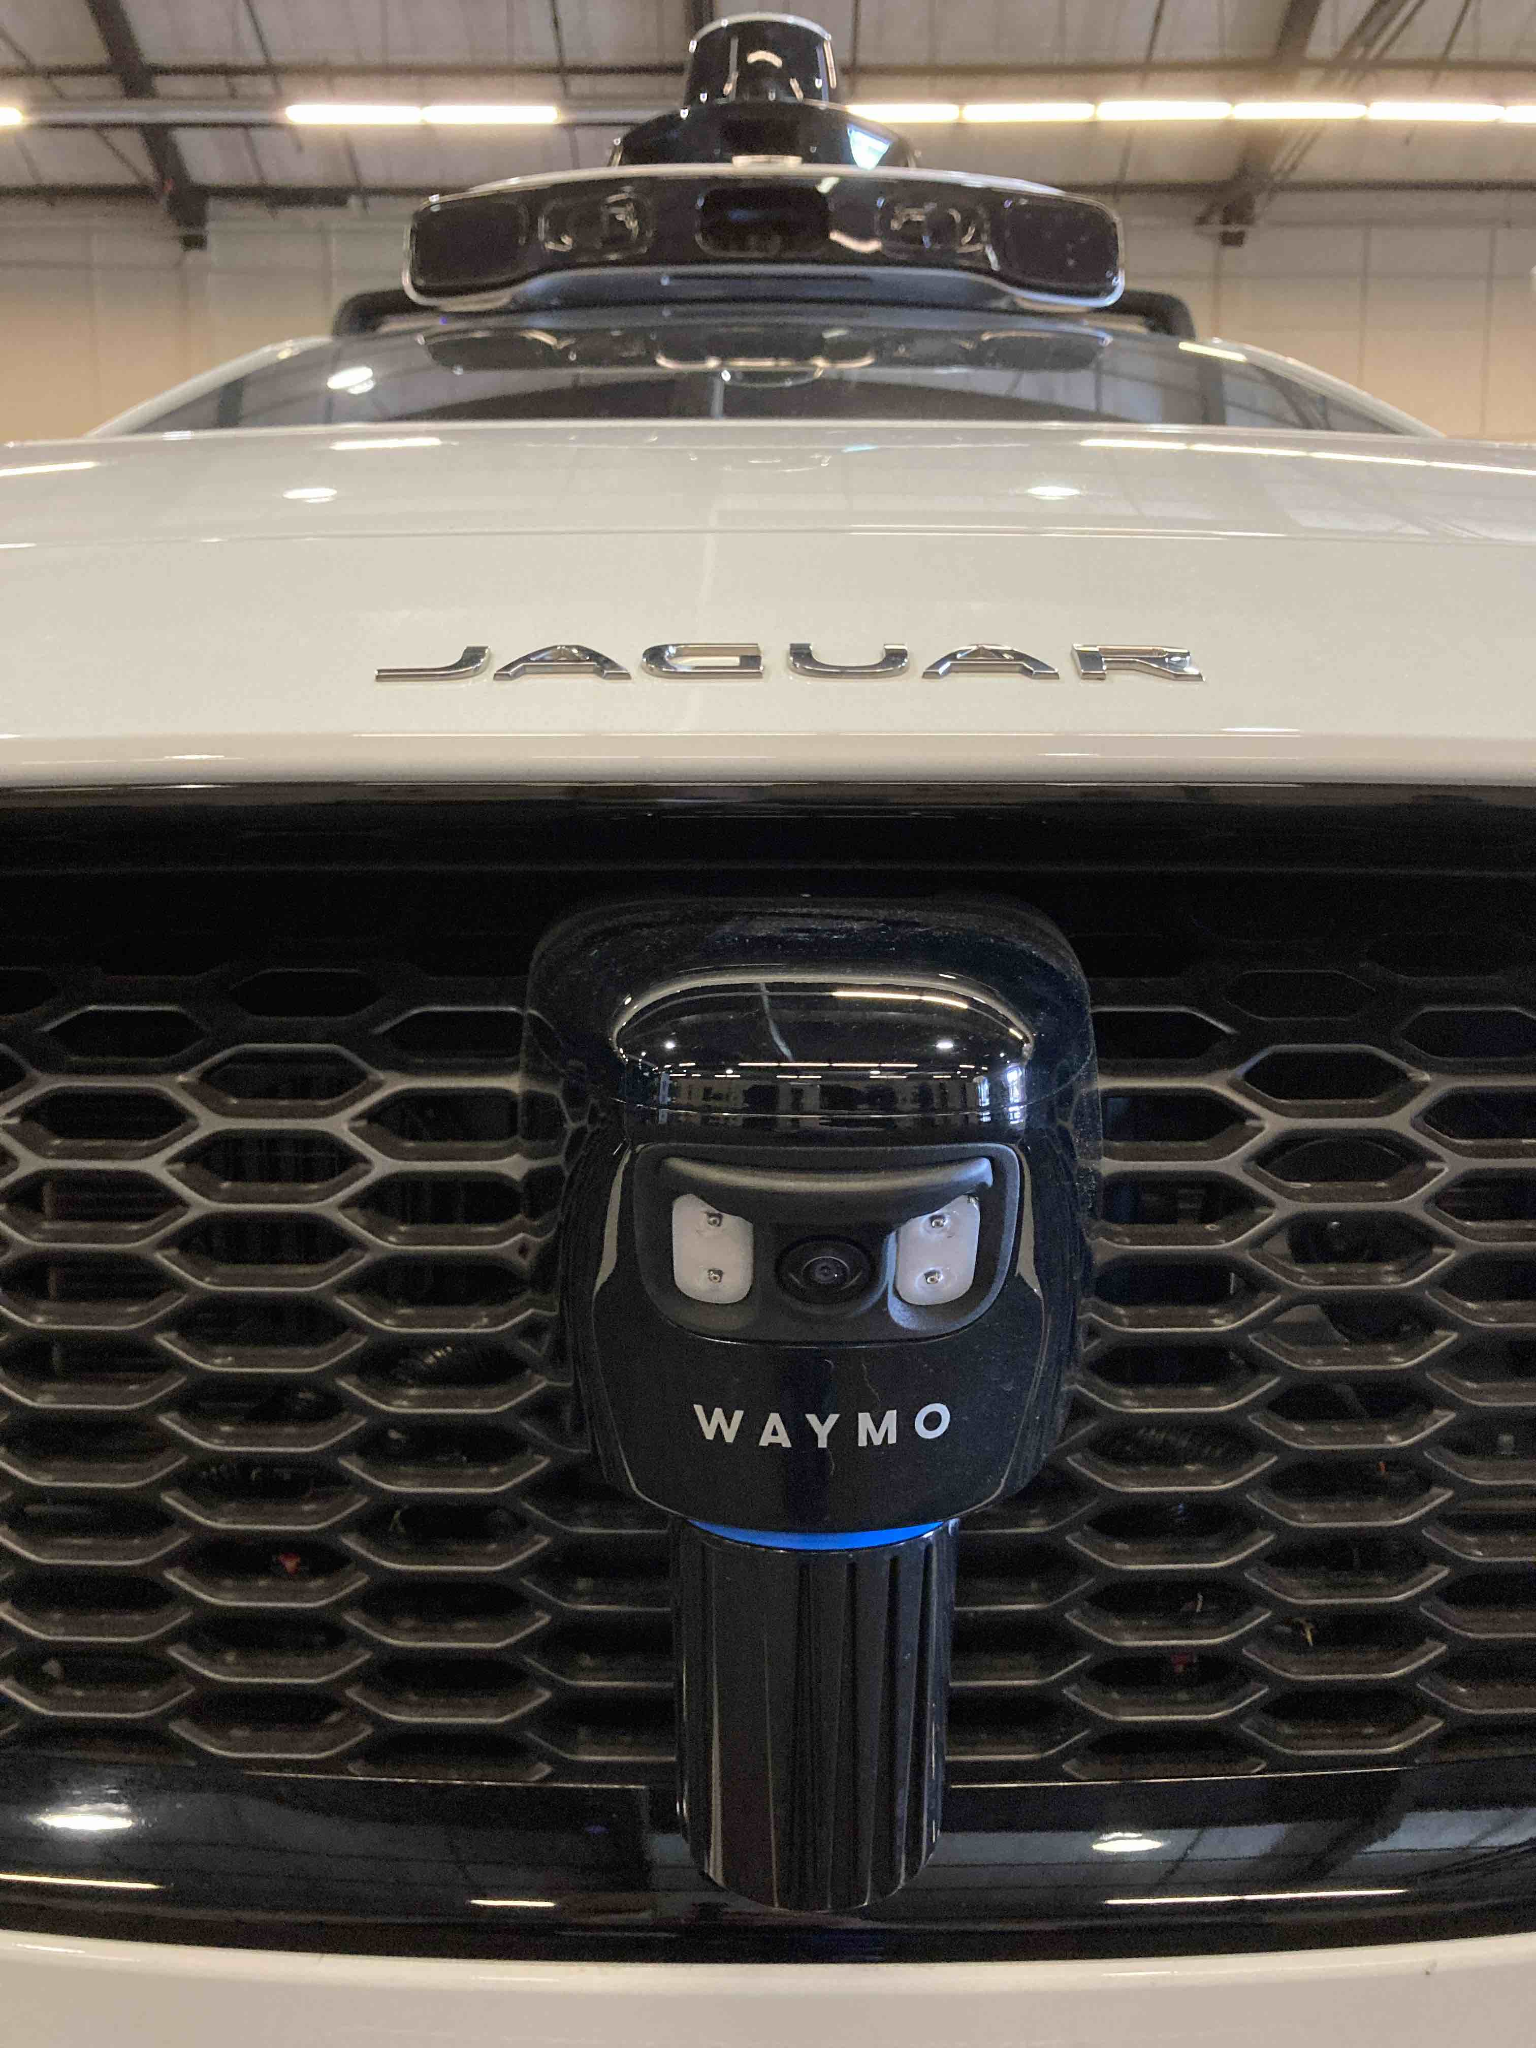
Robots often struggle with glass, hidden objects, shadows, and reflections. A 2026 study combined vision with camera movement and achieved a 96% success rate when grasping different types of objects.
The Image Is Processed
The captured image may be dark, noisy, blurred, or affected by shadows. The vision software processes the image to identify the objects in it.
Newer robots are also using event cameras. These cameras record changes in brightness instead of capturing complete frames. They are particularly useful for reducing motion blur when objects are moving and allow robots to work better in low-light conditions. Researchers have used them with robotic arms for grasping objects in difficult lighting.
Agricultural robots face strong sunlight and shadows. FieldNet, for example, is a real-time shadow-removal system developed for field robots. Reducing shadows helped improve weed detection.
The Robot Looks For Features
Next, the robot needs to identify the objects in the image.
The robot looks for useful features such as edges, colours, shapes, corners, and textures. For example, a robot sorting objects can use their shape, colour, size, and position to tell them apart.
The Robot Identifies The Object
Once the system finds these features, it can identify the object. A trained vision model compares the patterns in a new image with patterns it learned from many examples in its large database.
Latest vision models can also help robots recognise objects they have not seen before. Research such as DINOBot uses features from vision foundation models to help robots recognise and interact with unfamiliar objects.
More articles on this topic
36 articles ReportRobots vs. Drones: What Is the Real Difference?
 ReportHow Animals Inspire Better Robots
 ReportFrom Toys to Tools: The Coolest Robots in Schools Today
 ReportJapan Tests Robot Bins at Tokyo’s Busiest Railway Station
 ReportFive Extreme Sports Where Robots Are Competing
 ReportUnitree Adds $6,500 Dex5-S to Dexterous Hand Lineup
 ReportChina Raises Scrutiny of Humanoid Robot IPOs After Unitree Shares Fall 55%
 ReportViam Debuts Box-Opening Robot at IROS 2026
 ReportBoston Dynamics Opens New Home For Training Robots
 ReportHuman Gets in the Ring With a Six-Foot Humanoid Robot
 ReportBatteries Included: Why Staying Powered is Hard for Robots
 ReportGeek+ Opens Düsseldorf Lab for Live Warehouse Robot Demonstrations
BUSINESS NEWS WEEKLY LETTER
The Weekly Letter for Robotics Professionals, Summarizing the Most Important Industry Moves, Launches, Deals and Signals.